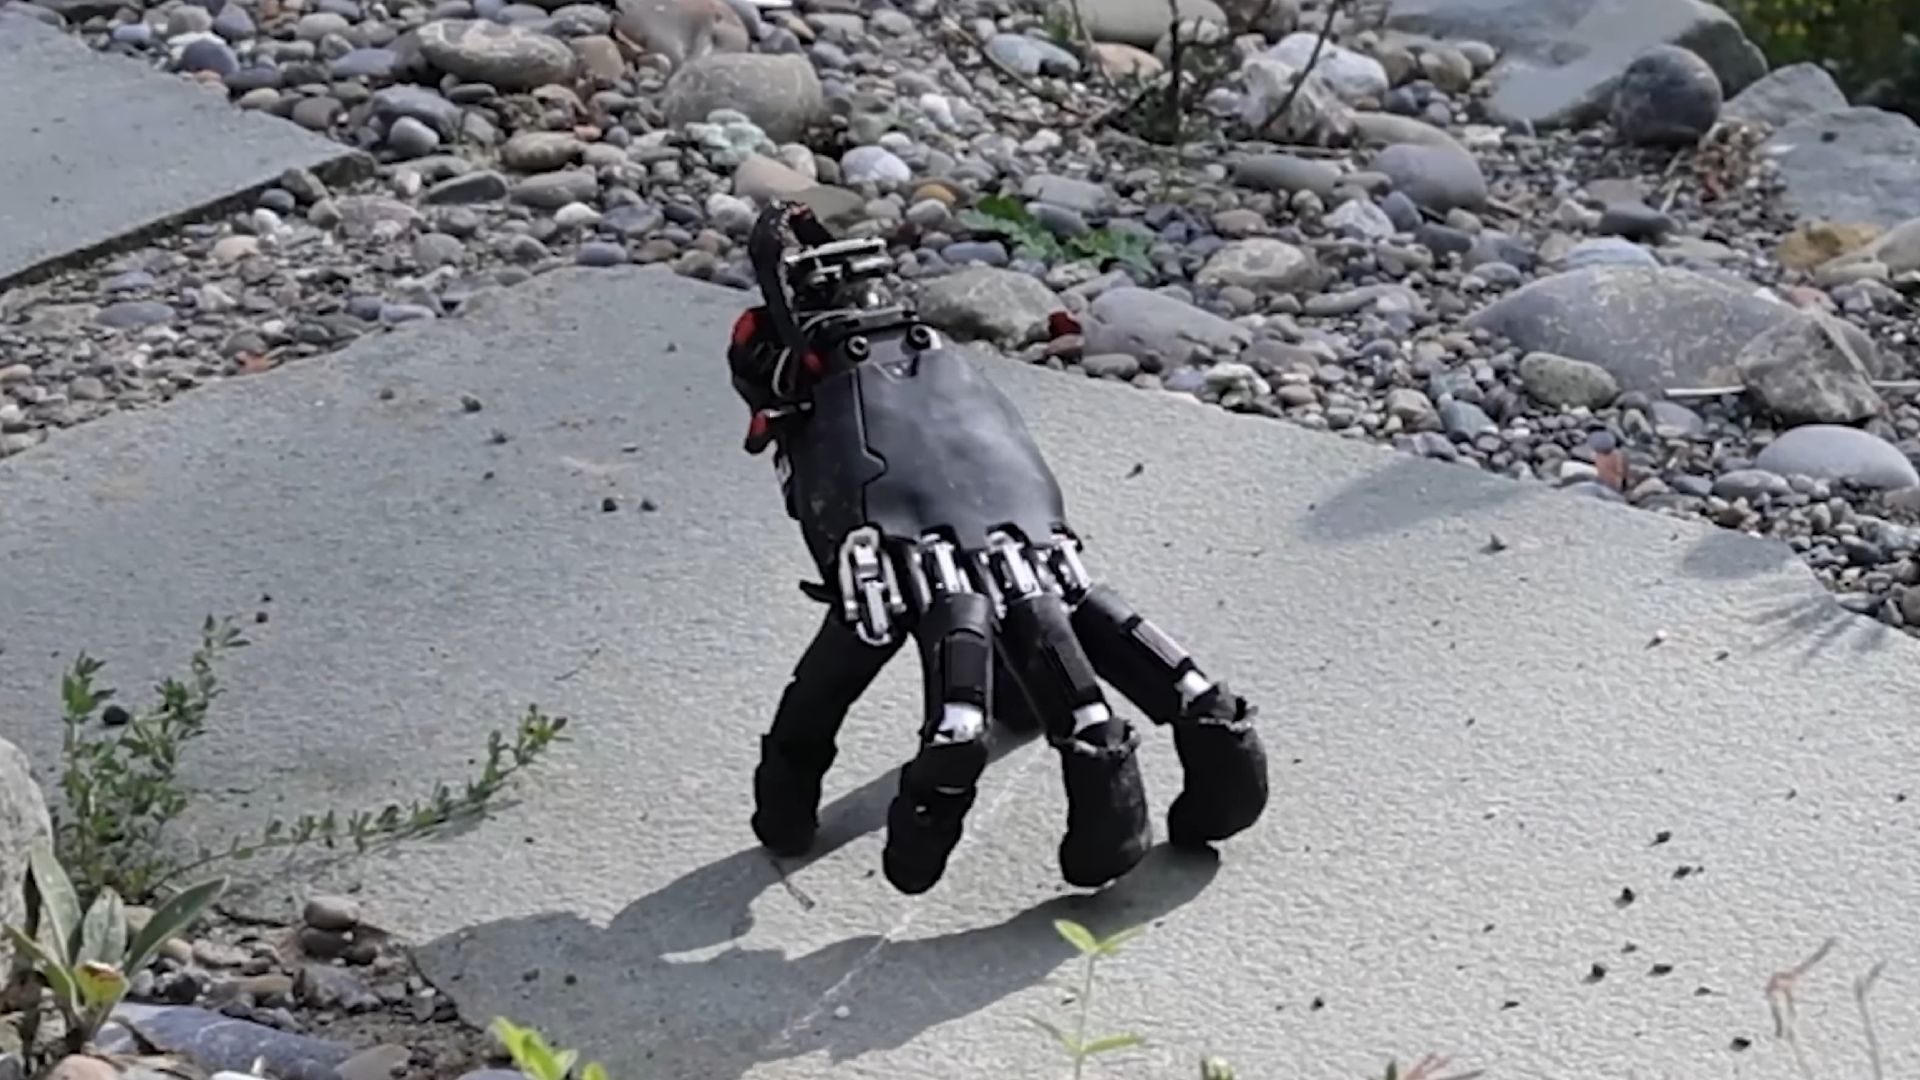
Thing, is that you? Watch this disembodied AI robot hand ‘walk’ like a terrible spider from the depths of my nightmares
Researchers at ETH Zurich have developed a disembodied robot hand capable of autonomous locomotion using its own fingers as legs. The four-jointed mechanical hand, reminiscent of Thing from The Addams Family, uses neural net-trained software to control its shambling, spider-like gait.
The project demonstrates a novel approach to robotic mobility, where individual appendages can operate independently to move across surfaces. Rather than being merely experimental novelty, the technology has practical applications in robotics. Large robots with bulky frames could deploy these articulated hands to reach distant objects or navigate spaces their main bodies cannot access, effectively extending their operational range and capabilities.
The system leverages machine learning algorithms to iteratively calculate optimal movement patterns, allowing the hand to adapt to different terrains and obstacles. By training neural networks on various locomotion scenarios, the researchers created a system that achieves surprisingly coordinated movement despite the unusual morphology of a severed hand.
While the concept may seem unsettling—combining a disembodied appendage with artificial intelligence—the research represents a meaningful advance in biomimetic robotics and multi-joint coordination systems. The work opens possibilities for future robotic designs prioritizing modularity and adaptability, where specialized end-effectors can function semi-autonomously.